Hugging Face BlogLabs
Build a Robot Pick-and-Place Simulation with SimReady Assets

This walkthrough showcases a beverage can pick-and-place task that uses the UR17G arm , Robotiq 2F-140 gripper , and beverage can to compose a scene in Isaac Sim, check their behavior, and run a…
Read at Hugging Face Blog ↗Related

ResearchVideo Friday: NASA PROMISEs a New Moon Rover IEEE Spectrum Robotics

SiliconAdapt Human Motion for Robots with NVIDIA SOMA Retargeter NVIDIA Technical Blog
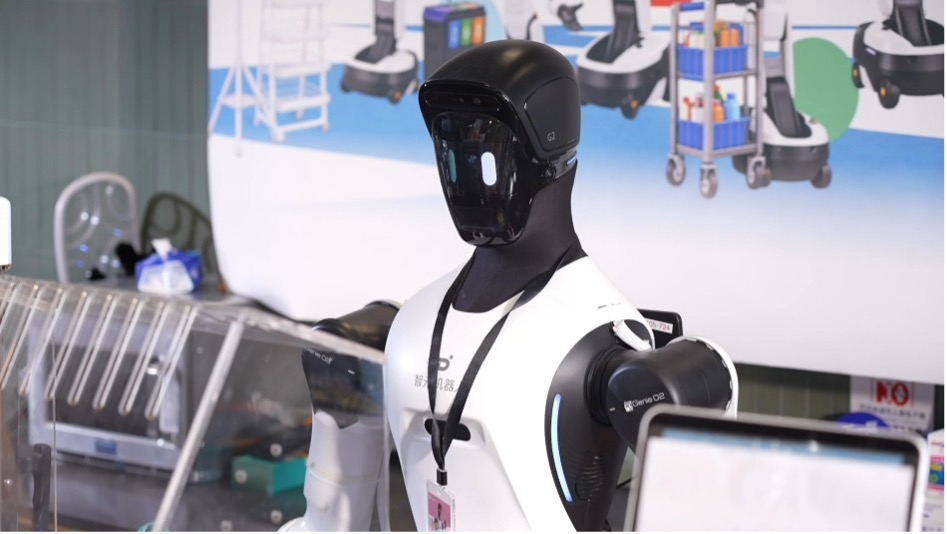
ResearchSix AGIBOT G2 Robots Complete 1,730 Tasks in 24-Hour Shanghai Convenience Store Trial The Robot Report

Siliconelectronica 2026: Chipmakers Move Up the Stack as Data Centers and Physical AI Take Center Stage EE Times
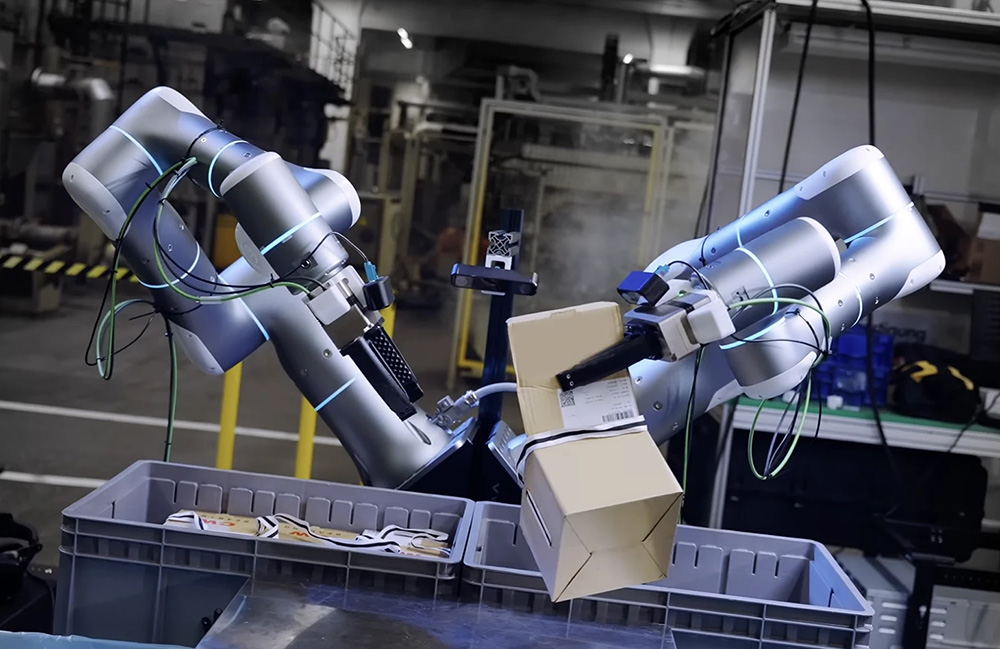
ResearchHow Rhoda AI is using video data to create generalized AI models for robots The Robot Report